The full data pipeline for physical AI: wearables that capture touch, an operator network across India, annotation, simulation, and robot policies trained and deployed on real hardware.
Ships to the stack you already train on
The platform
We own every step, so the data, the sim assets and the policy come out of one system instead of five vendors.
Open-source rigs and in-house designs like TENET record contact on every fingertip.
Partner vendors and our in-house operations team record demonstrations across India.
Raw data becomes robot-learning datasets and environments, in standard training formats.
Real objects and factory data become physics-ready assets for validating policies.
State-of-the-art models, trained for your specific use case on our datasets.
On real robots in real environments, including customer robots in our partner factories.
Product
The operator's RGB view, measured contact rendered on the hand model, and raw 4×4 velostat pressure maps for thumb and index, on one clock.
Partner vendors and our in-house operations team record demonstrations across India with gloves, UMI grippers and other open-source rigs. Every episode ships in the formats teams already train on.
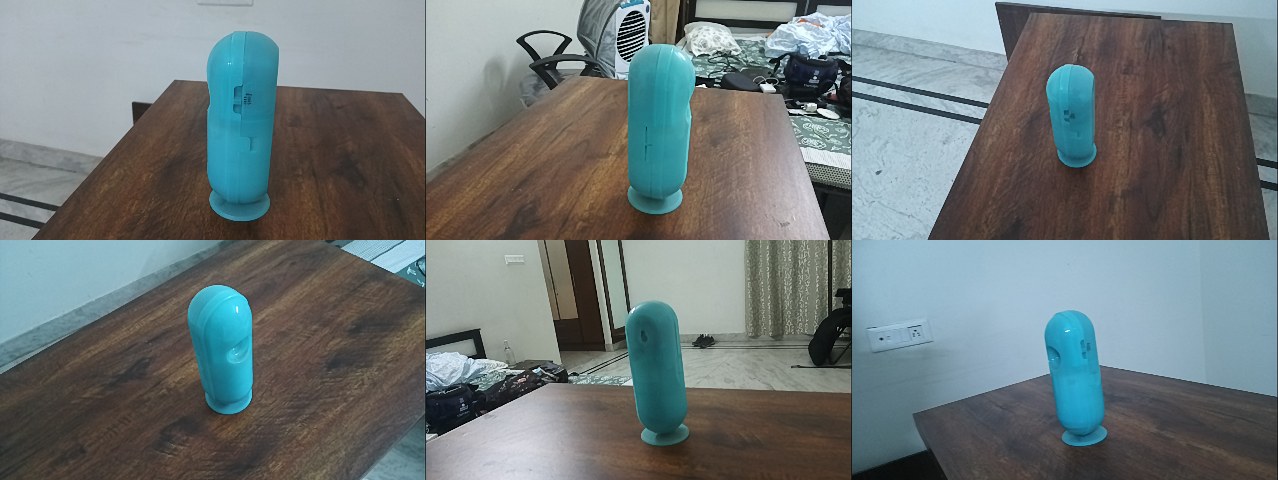
Photograph the objects at your site and we return watertight, physics-ready twins. We also turn raw factory data into realistic assets for validating trained policies.
Our diffusion trajectory policy learns manipulation directly from egocentric human video. No teleoperation, no lab capture. Here it opens an unseen door on a real robot.
Talk to us about a pilot →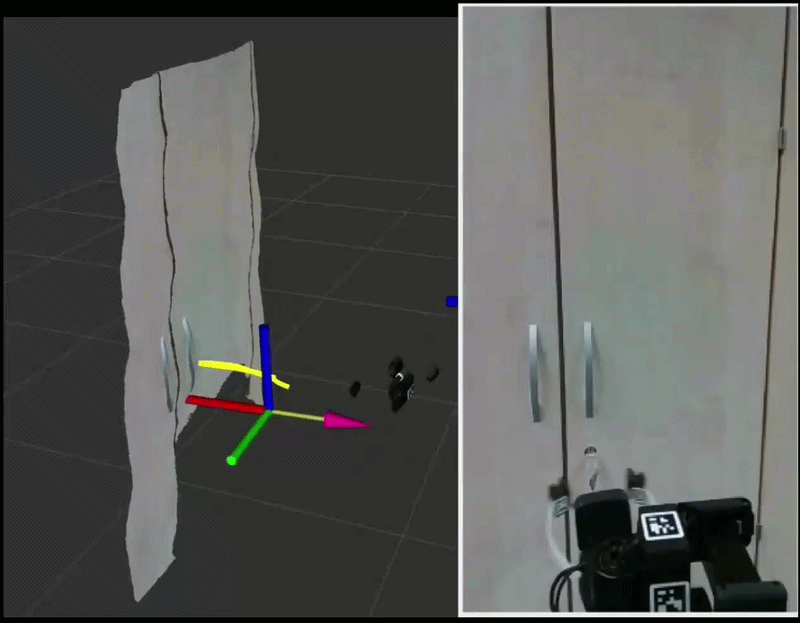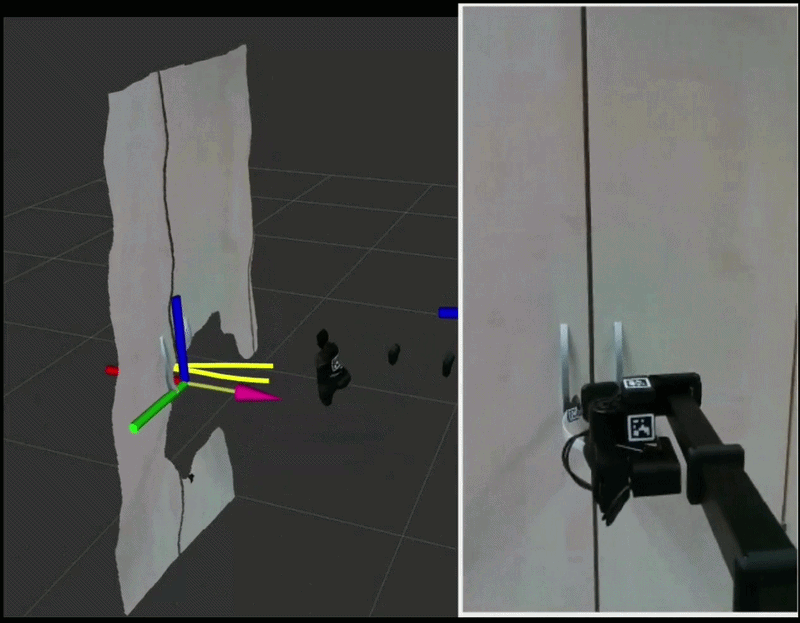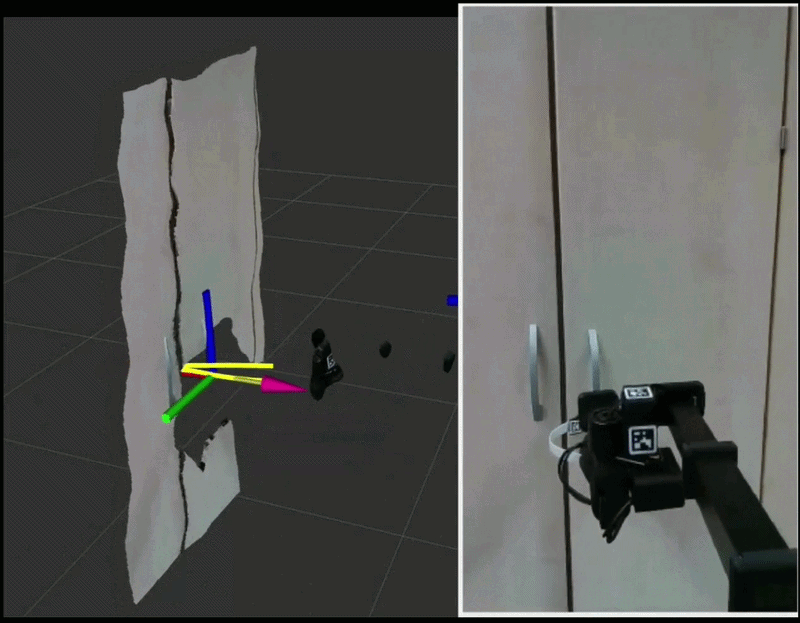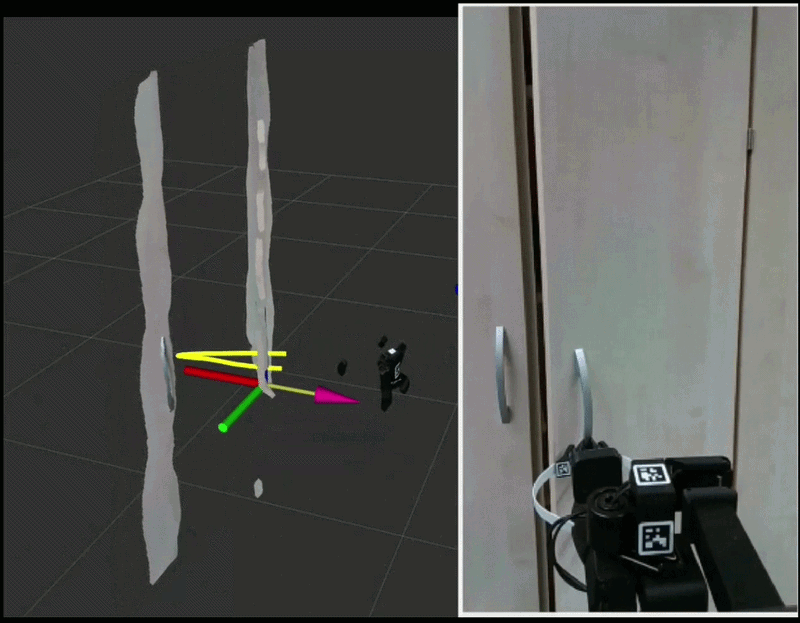
Sample pack
Every sample pack is real data from our pipeline, documented so your team can load it into your training stack. We get back to you within 48 hours.
Request a sample pack →Team & careers
We're looking for ambitious people who take ownership. If that's you, write to us.
 Kavya ShankarFounder · LinkedIn ↗
Email us about sample data, reconstructions, pilots, or roles. We get back to you within 48 hours.
